Jiajie Zhang 「张嘉杰」
Research Assistant at PEAK Lab, HKUST-GZ

I am currently a Research Assistant at PEAK Lab, HKUST-GZ, working with Professor Changhao Chen. I received my Master’s degree in Computer Science and Technology from ShanghaiTech University (2023 - 2026), advised by Professor Sören Schwertfeger at the MARS Lab (Mobile Autonomous Robotics Systems Laboratory). I received my B.S. in Automation from Zhengzhou University (2019 - 2023).
I am fascinated by the essence of intelligence, and representation learning may well be one of the keys to understanding and creating intelligence. Endowing robots with such intelligence and the ability to act in the real world is what excites me most, and my research interests center on robot learning for manipulation. I also see enduring value in classical robotics; combining it with robot learning through structure and data is the direction I believe in.
For more details, please visit my publications, projects, or CV.
Jiajie's Journey
-
2016–2019
Cixi High School
Kid :)
-
2019–2023
Zhengzhou University
Bachelor
-
2023–2026
ShanghaiTech University
Master
-
2026–Present
HKUST(GZ)
Research Assistant
-
Upcoming
TU Darmstadt
Incoming PhD Student
News
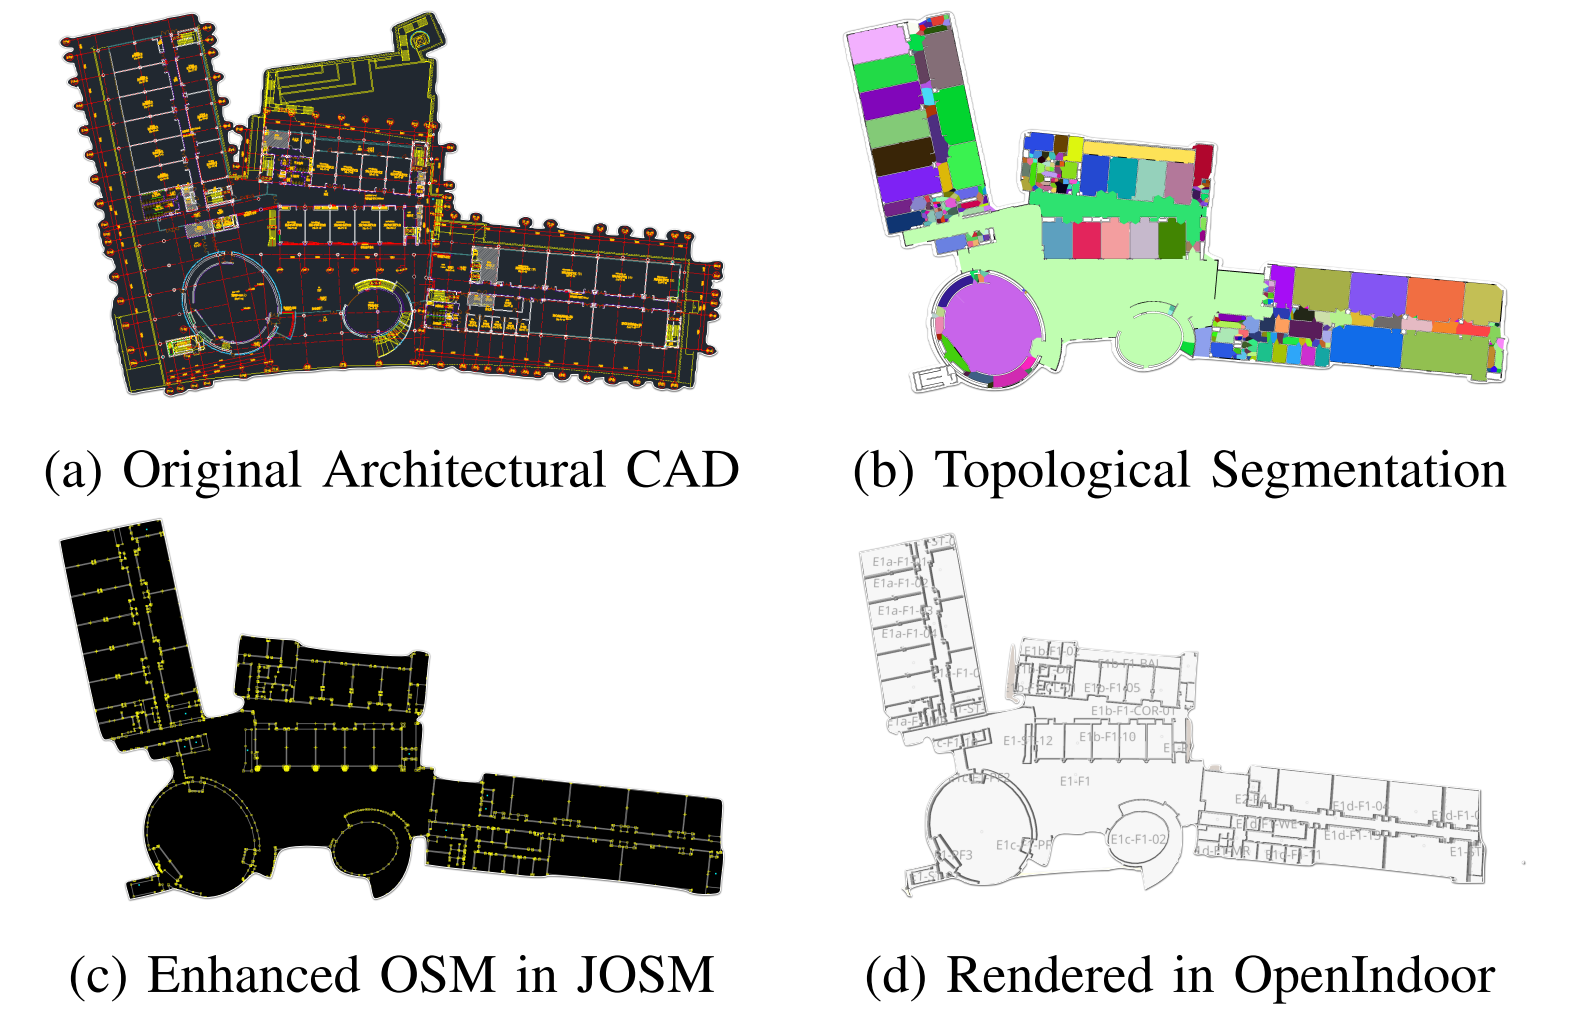
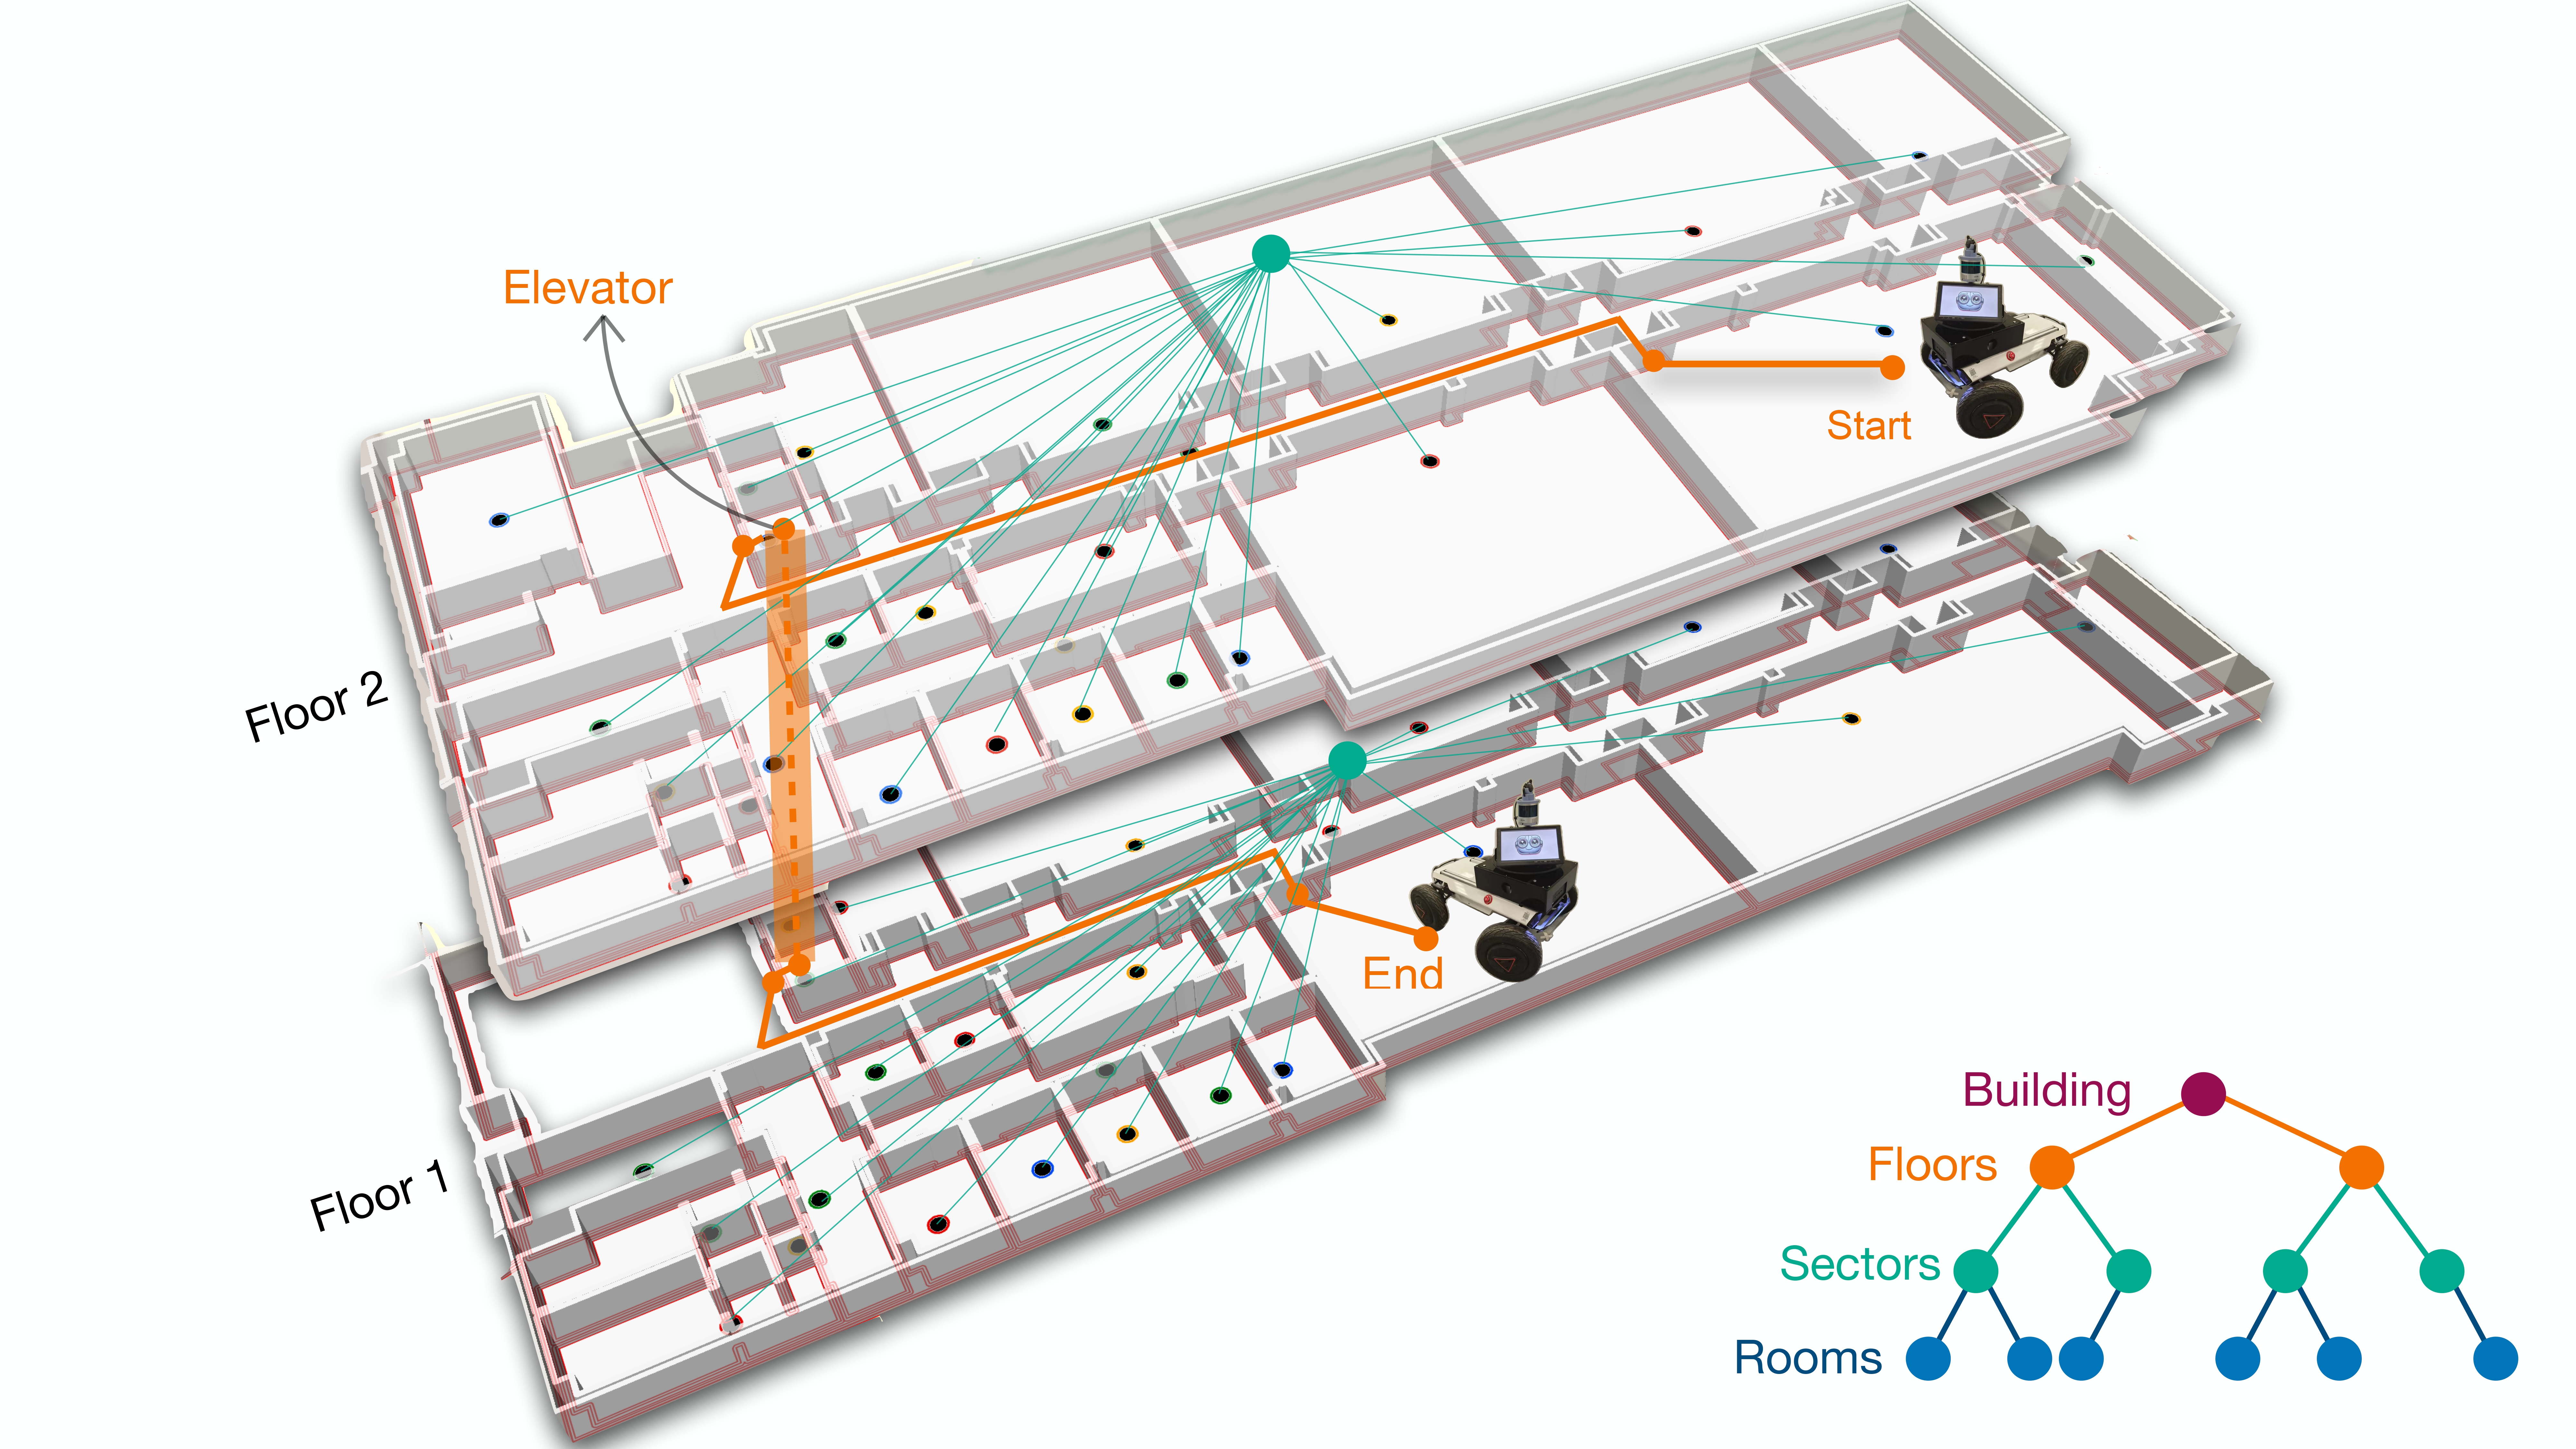
| Jun 17, 2026 | Our paper Generation of Indoor Open Street Maps for Robot Navigation from CAD Files has been accepted by IROS 2026! 🎉 |
|---|---|
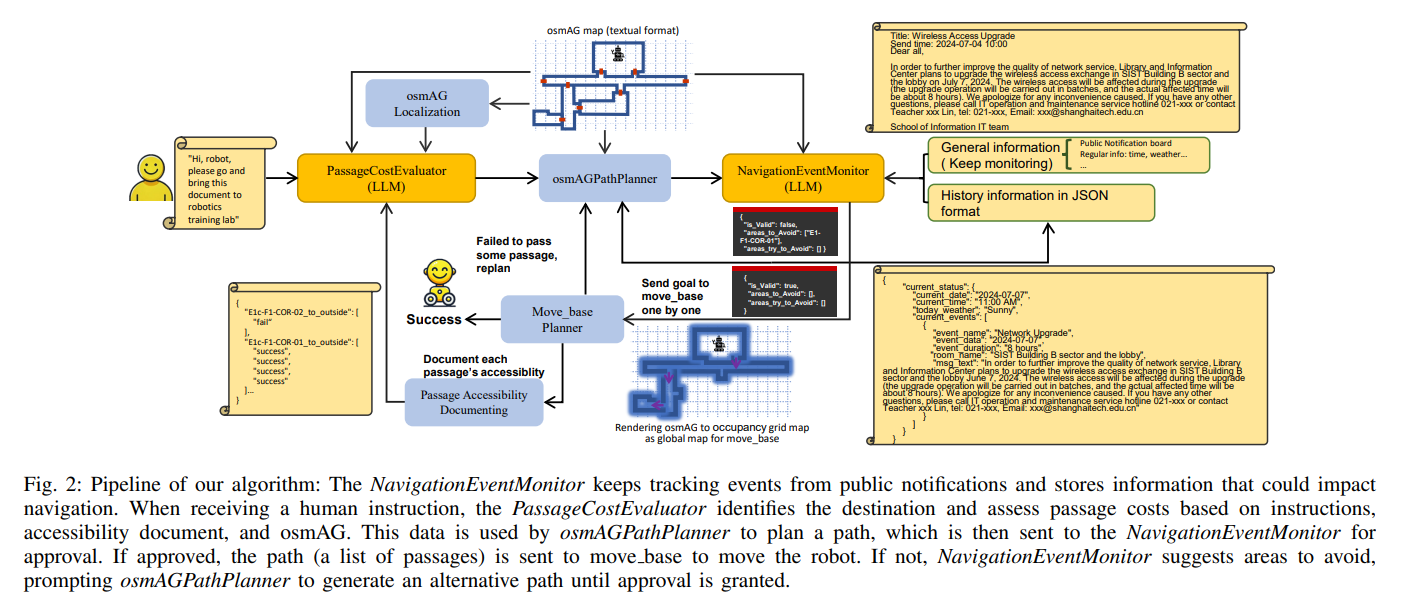
| Apr 01, 2026 | Our paper osmAG-Nav: A Hierarchical Semantic Topometric Navigation Stack for Robust Lifelong Indoor Autonomy is now available on arXiv! |
| Feb 23, 2026 | Our paper From Observation to Action: Latent Action-based Primitive Segmentation for VLA Pre-training in Industrial Settings has been accepted to CVPR 2026! 🎉 |
| Jul 07, 2025 | Research Assistant at AI R&D Center, Central Research Institute, Wolong Electric (July–October). Supervised by Dr. Alexander Kleiner. |
| Jul 01, 2025 | New preprint on Generation of Indoor Open Street Maps for Robot Navigation from CAD Files is now available on arXiv! |
Publications
-
-
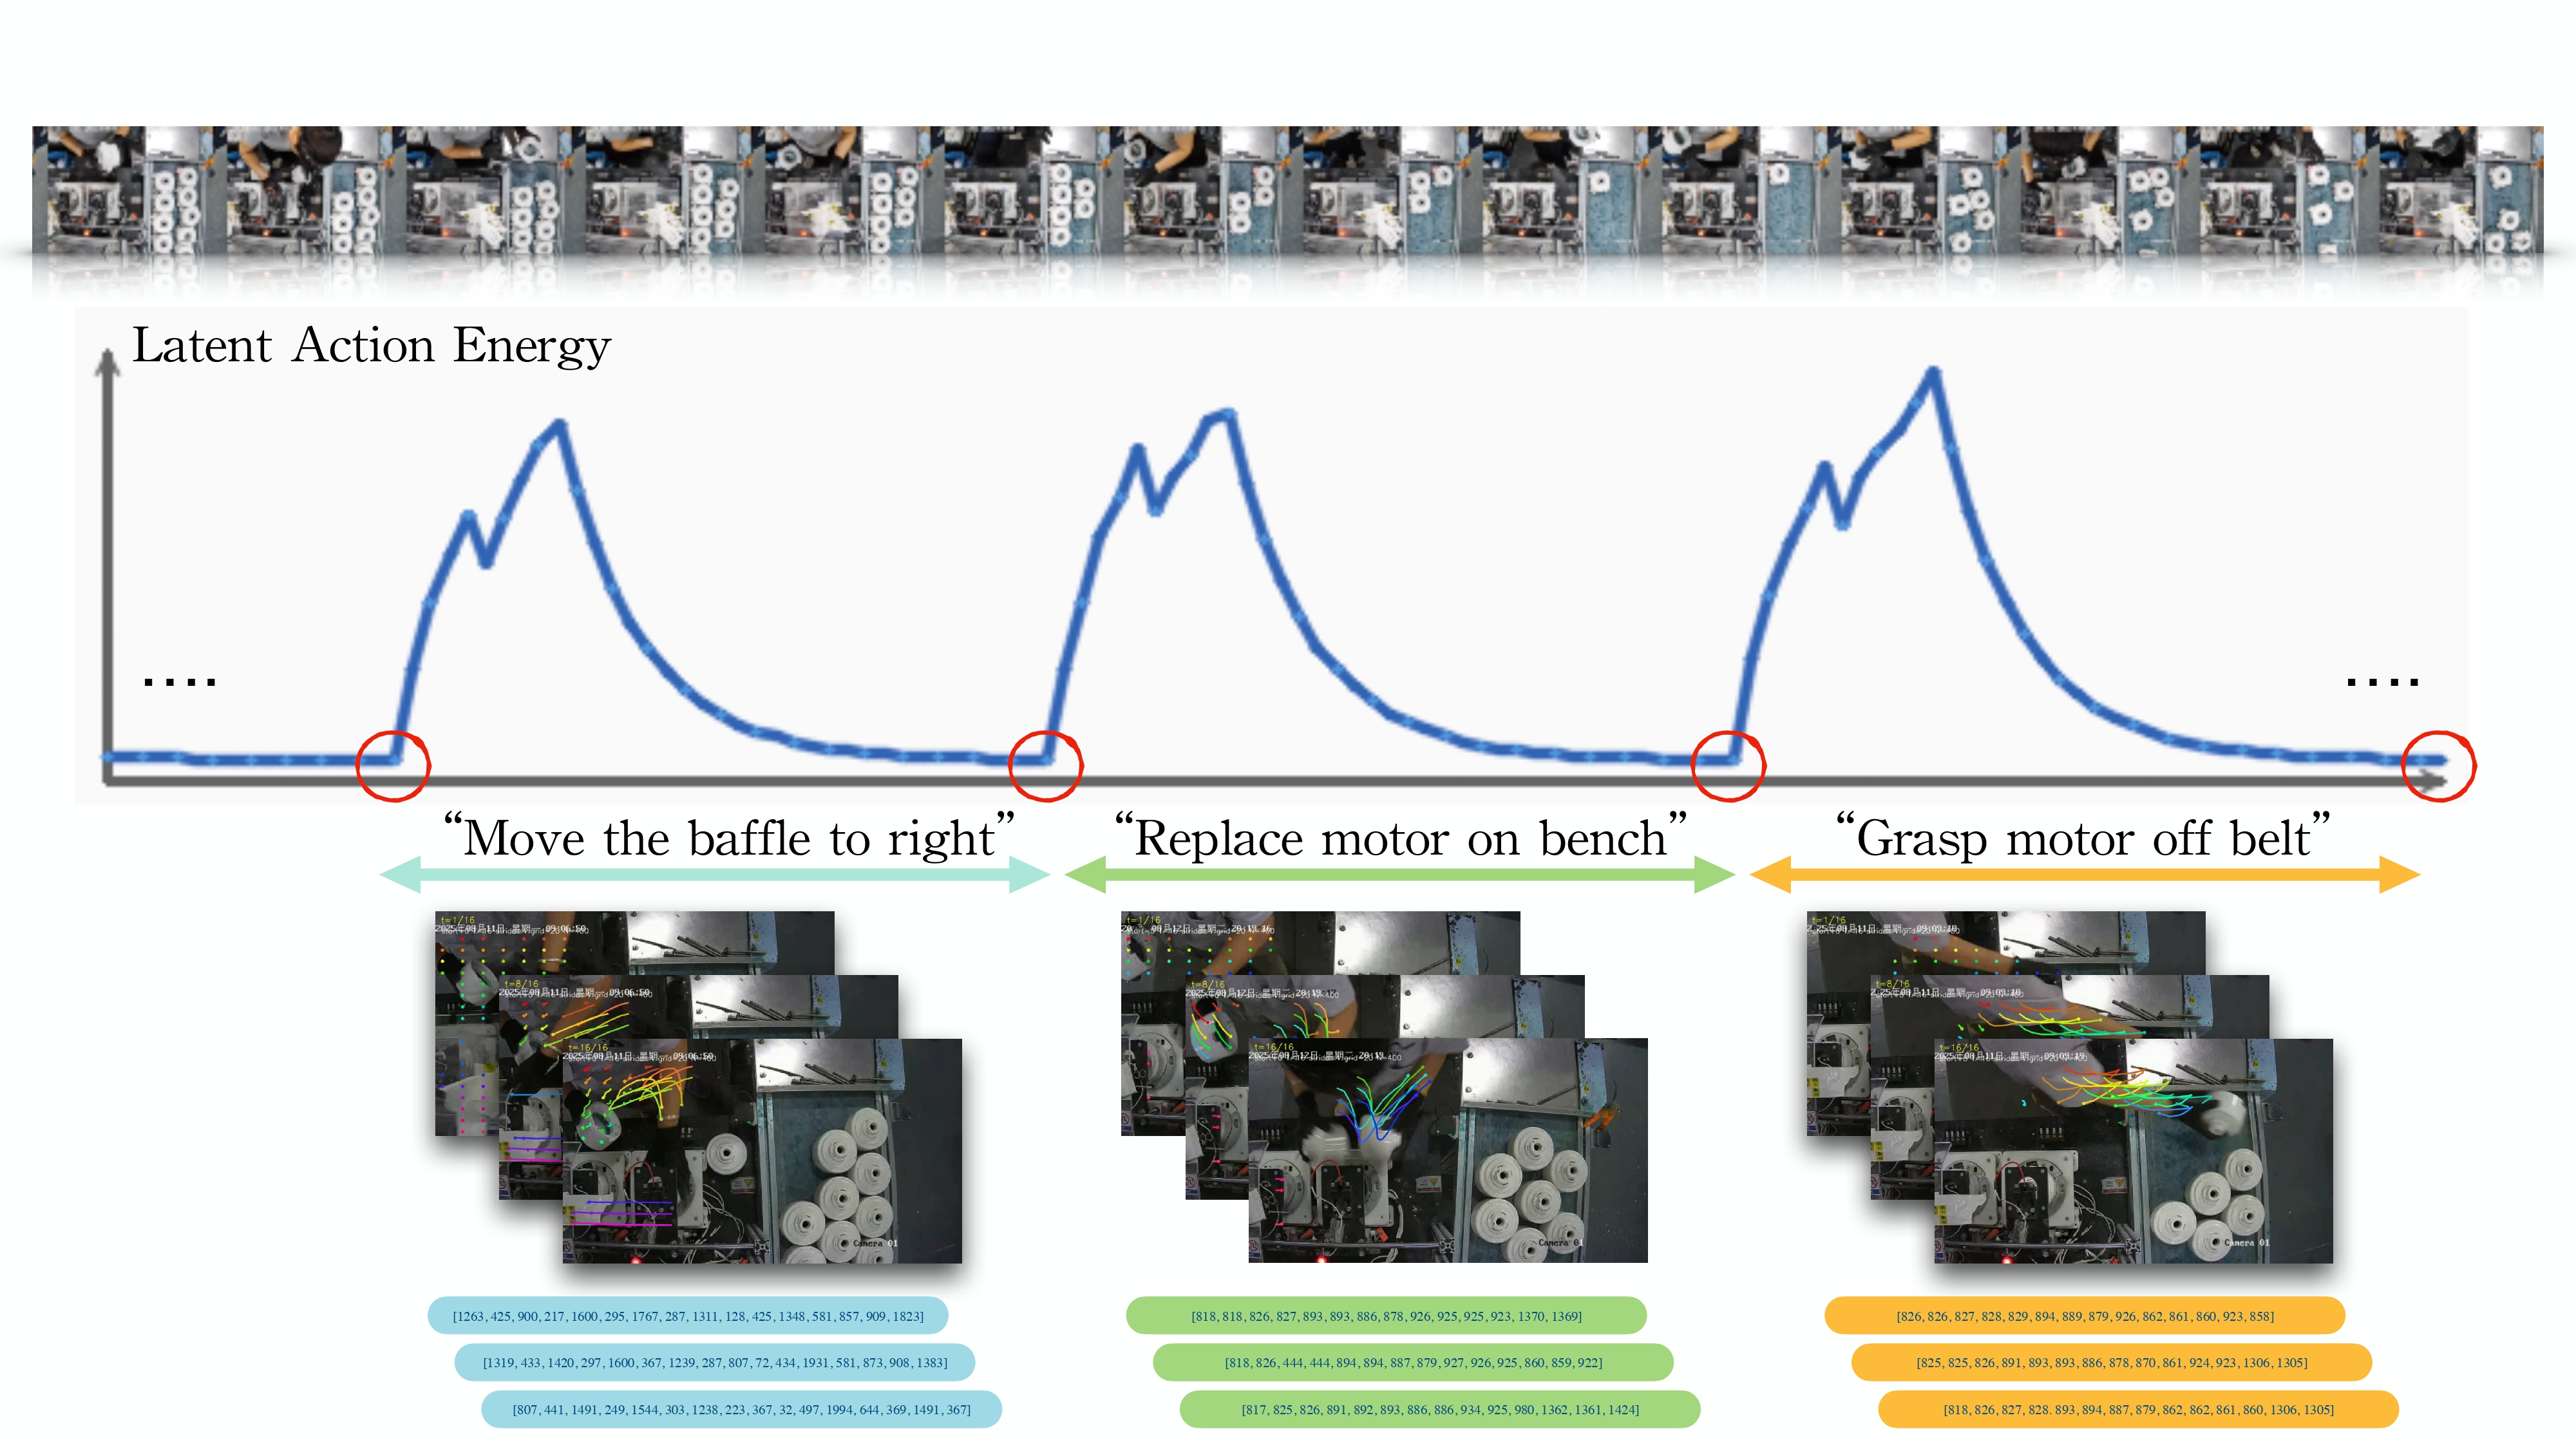 From Observation to Action: Latent Action-based Primitive Segmentation for VLA Pre-training in Industrial SettingsCVPR 2026
TL;DR: An unsupervised framework segments industrial demonstration videos into action primitives and latent action sequences for VLA pre-training.